UniMate for Agents
Animate any rigged skeleton from a sentence. UniMate (SIGGRAPH Asia 2026) on a ZeroGPU slice: one synchronous call returns an animated GLB, raw motion features, joint positions and a preview. Then keep what you like and regenerate the rest: in-betweening, joint editing and multi-prompt expansion, the upstream editing modes, verified end to end.
Guide /llms.txtOpenAPI /openapi.jsonSwagger /docsMCP /gradio_api/mcp/Gradio schema /gradio_api/infoService /api
Give this to your agent
Read https://townbox-unimate-for-agents.hf.space/llms.txt and use UniMate to <WHAT_TO_ANIMATE_AND_WHAT_TO_DO_WITH_THE_FILES>. Use my configured Hugging Face token if available.
Connect over MCP
https://townbox-unimate-for-agents.hf.space/gradio_api/mcp/ · schema /gradio_api/mcp/schemaanimate (asset, prompt, num_samples, cfg_scale, seed, preview) · inbetween (reference_job_id, prompt, keep_frames, …) · edit_joints (reference_job_id, prompt, keep_joints, …) · expand (asset, prompts, overlap, …) · list_assets · get_result · view_animation (returns the contact-sheet PNG) · service_info · guideclaude mcp add --transport http unimate https://townbox-unimate-for-agents.hf.space/gradio_api/mcp/ --header "Authorization: Bearer $HF_TOKEN"{
"mcpServers": {
"unimate": {
"url": "https://townbox-unimate-for-agents.hf.space/gradio_api/mcp/",
"headers": { "Authorization": "Bearer <HF_TOKEN>" }
}
}
}First call: list_assets, then animate with a prompt that starts with “An object”; the result's file URLs download with the same header, and its job_id is the reference for inbetween and edit_joints. Signed in on the Hub, the Space's Agents menu also adds it to your Hugging Face MCP tools.
Examples generated by this Space
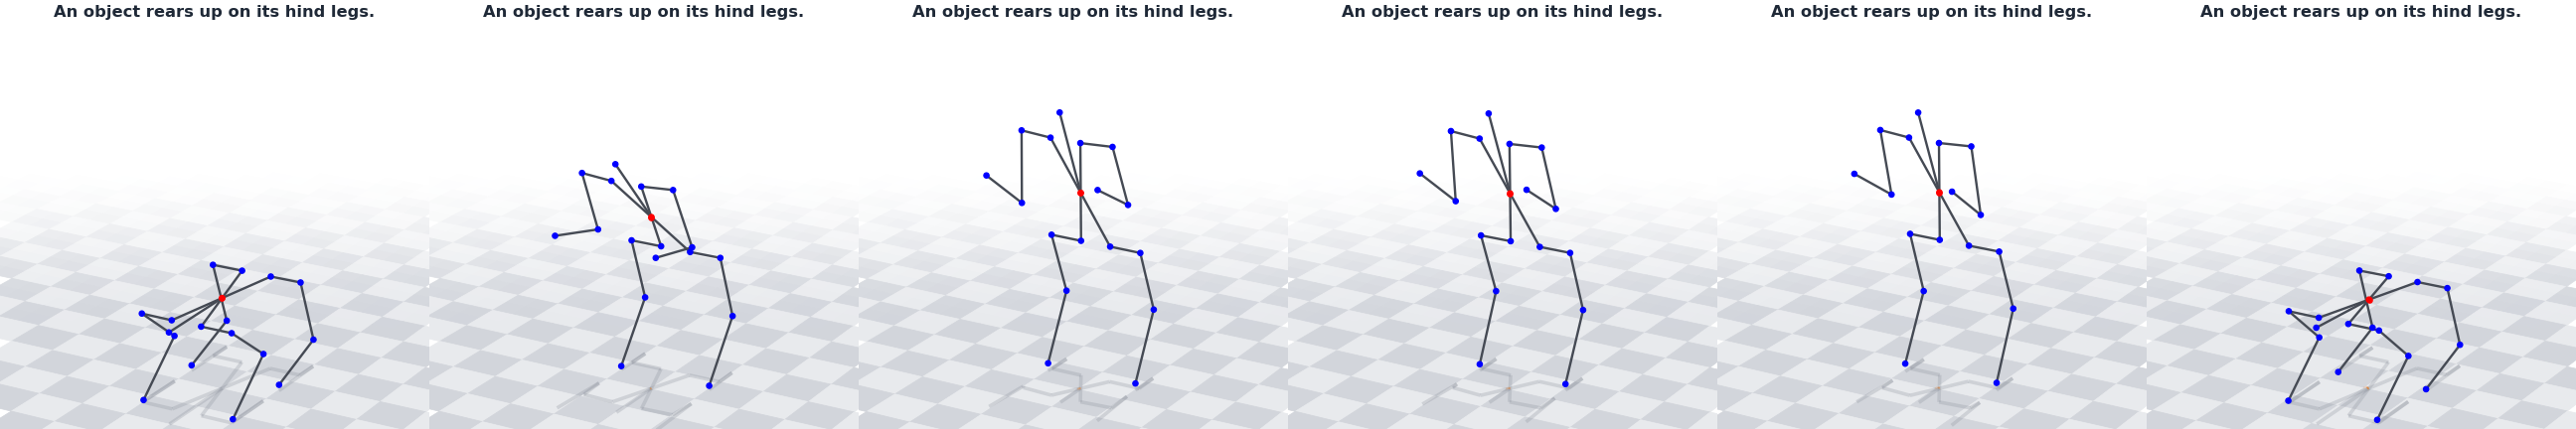
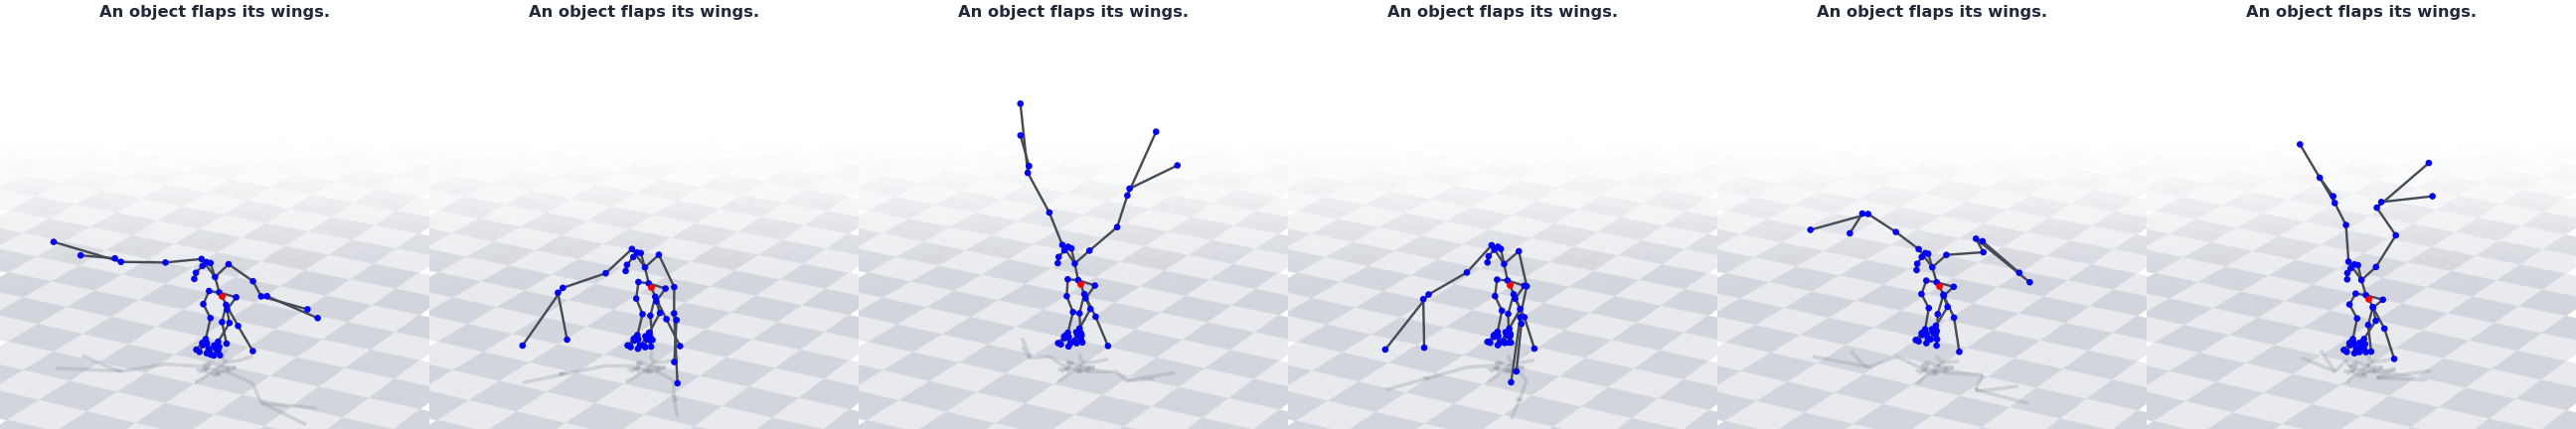
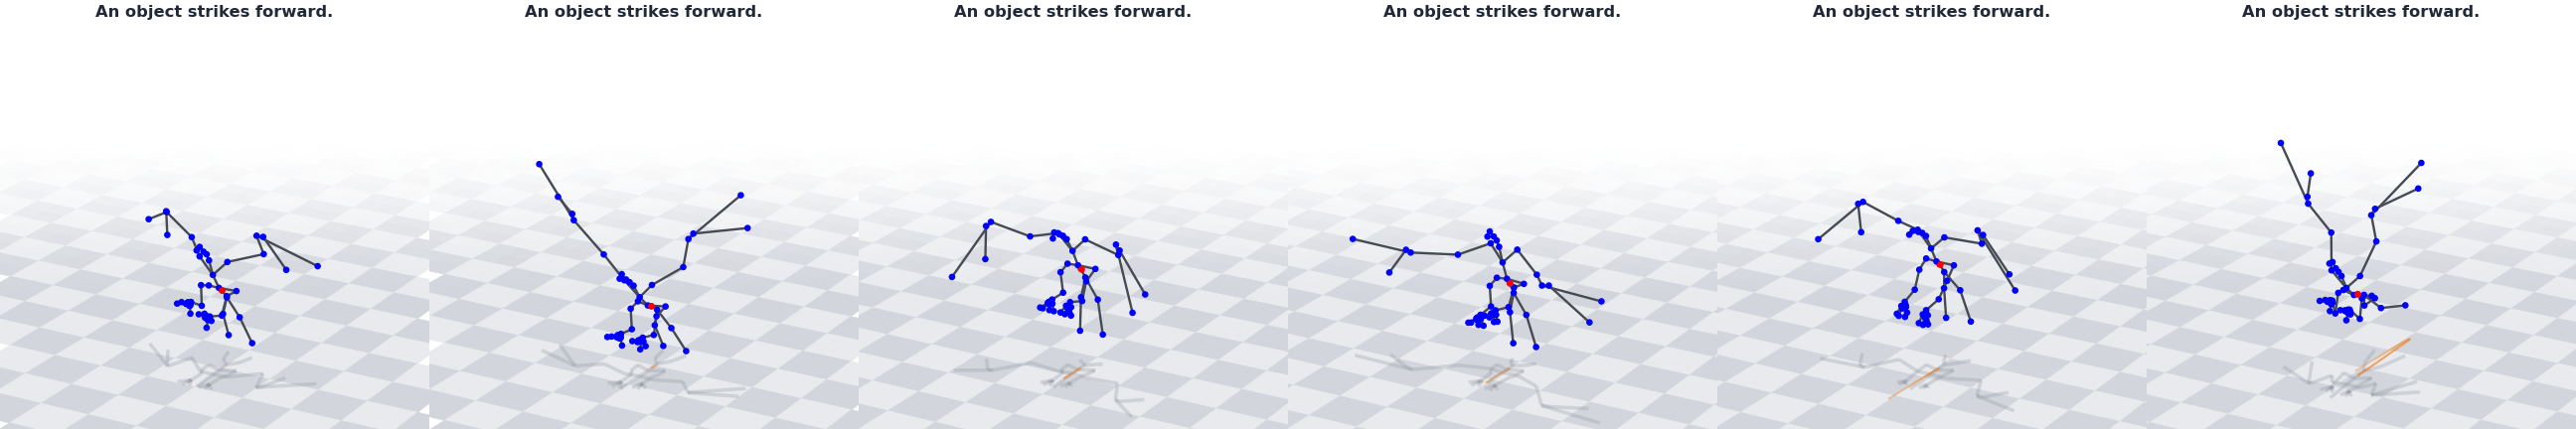
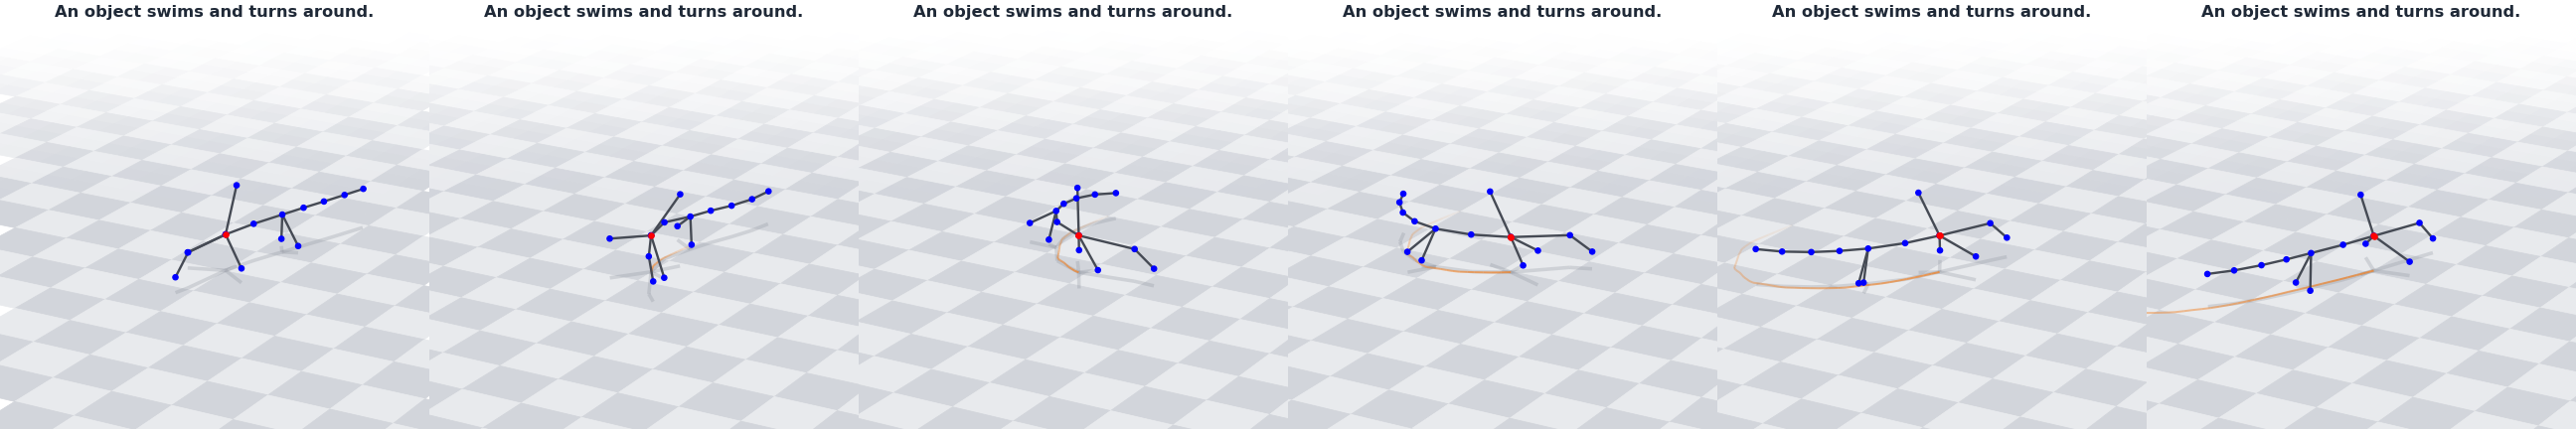
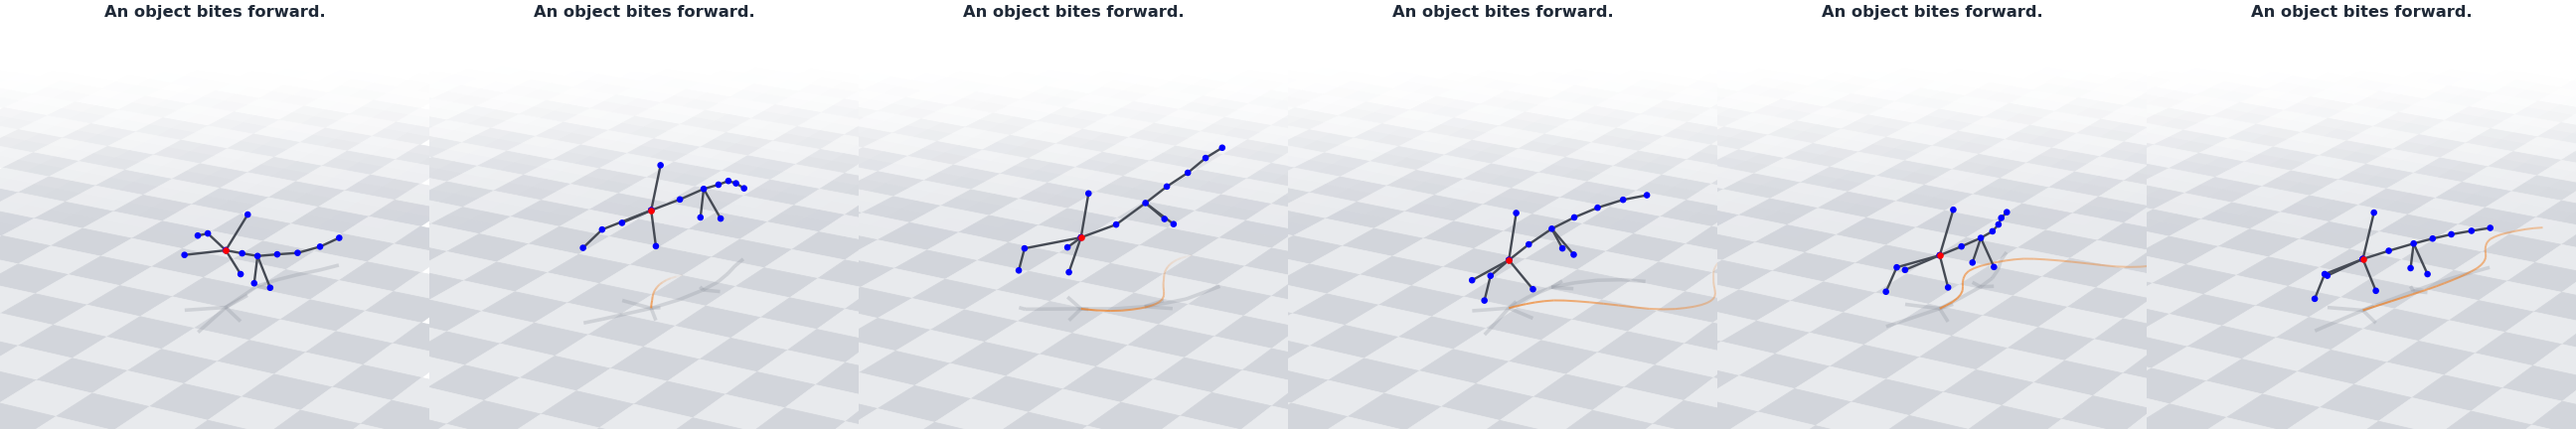
Nine real outputs of this API, produced on 2026-11-05 on the ZeroGPU slice with checkpoint unimate_uniml3d_f60_v3 step 150000 (ema weights): six by POST /api/animate, then one each by /api/inbetween, /api/edit and /api/expand (the three mode-verification runs). Click a picture to load the animated 3D mesh (drag to orbit); the video under it is the skeleton preview the API returns. The seeds reproduce them; the API always generates fresh results. Machine-readable list: /api/examples.
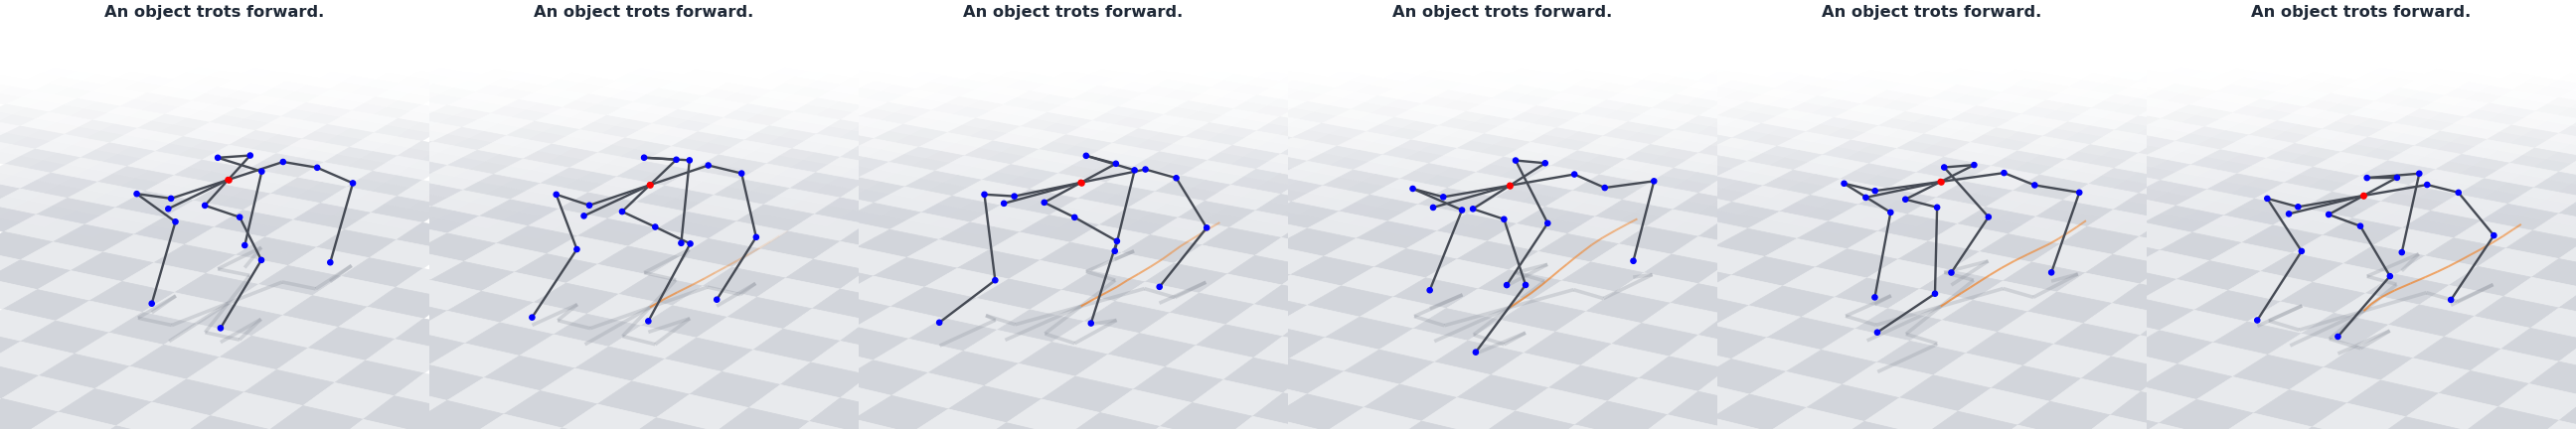
POST /api/inbetween, reference = the trot above (seed 7), keep_frames 0,-1 · seed 1 · cfg 3.0 · 3.1 s GPU · kept frames identical to the reference (max difference 1.2e-7)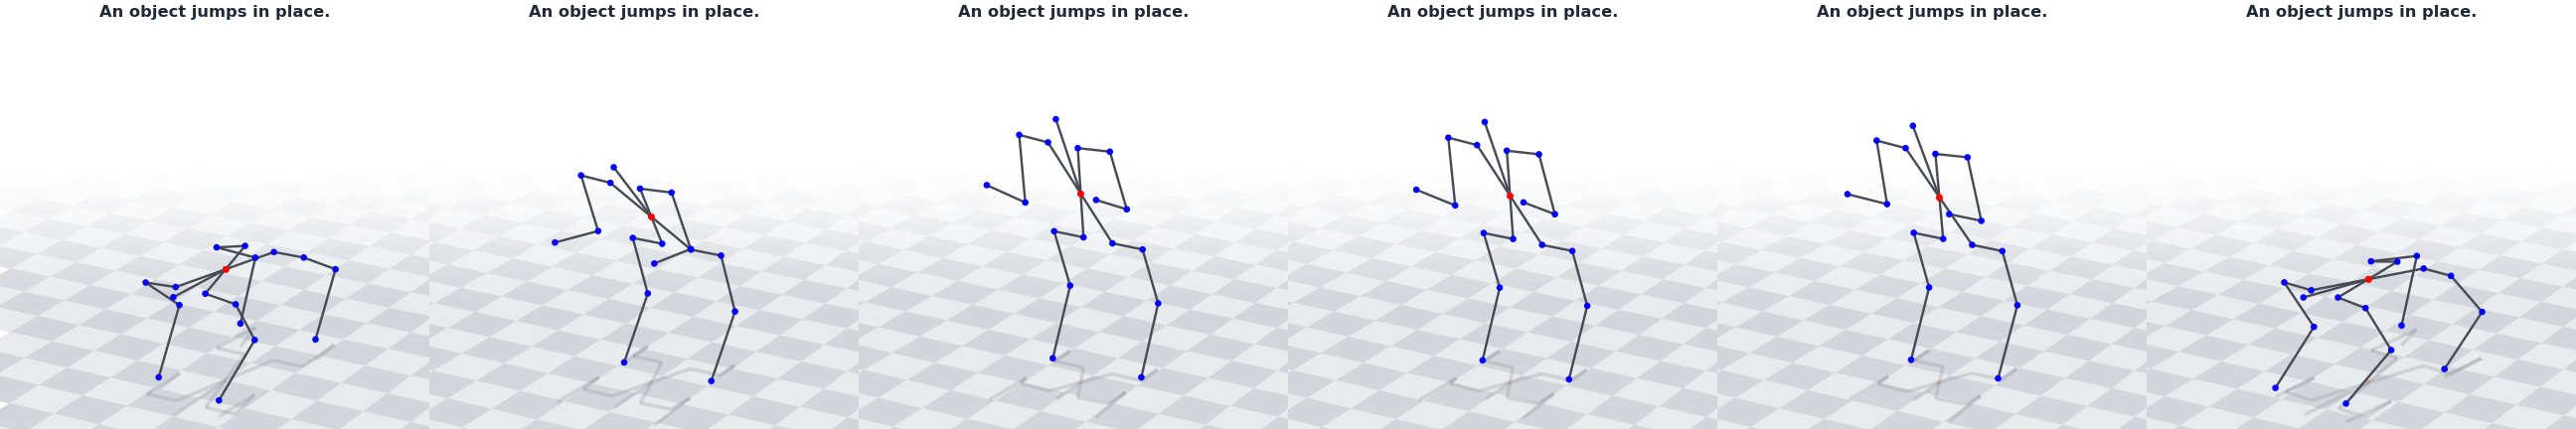
POST /api/edit, reference = “An object walks forward.” (seed 5), keep_joints = hips, thighs, shins, fetlocks, feet, toes (27 joints) · seed 4 · cfg 3.0 · 3.1 s GPU · kept joints identical to the reference (1.2e-7), 24 joints regenerated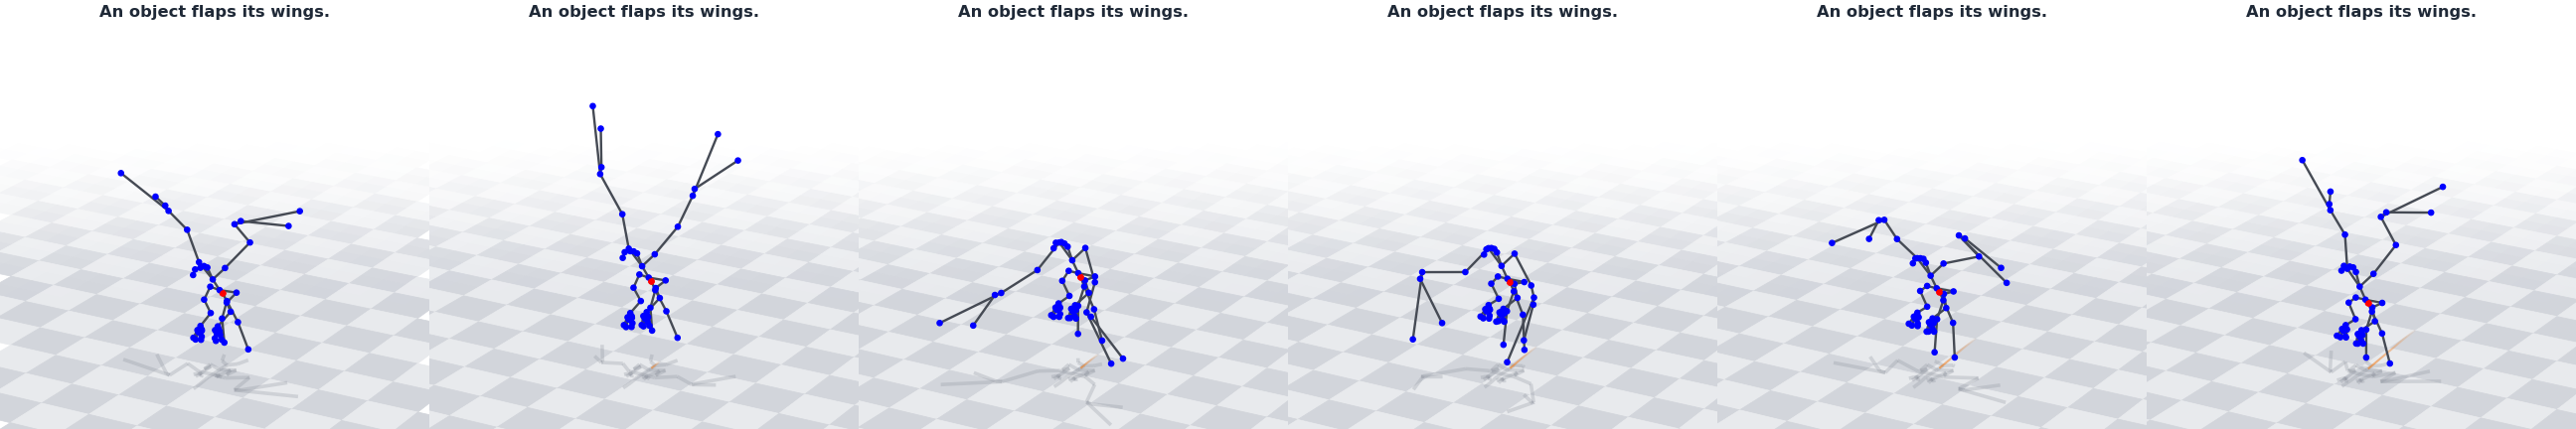
POST /api/expand, 3 prompts, overlap 10 · seed 7 · cfg 3.0 · 12.1 s GPU · root travel 4.54 · segments at frames 0, 50, 100 · GLB checked against Blender's importer (6.6e-6)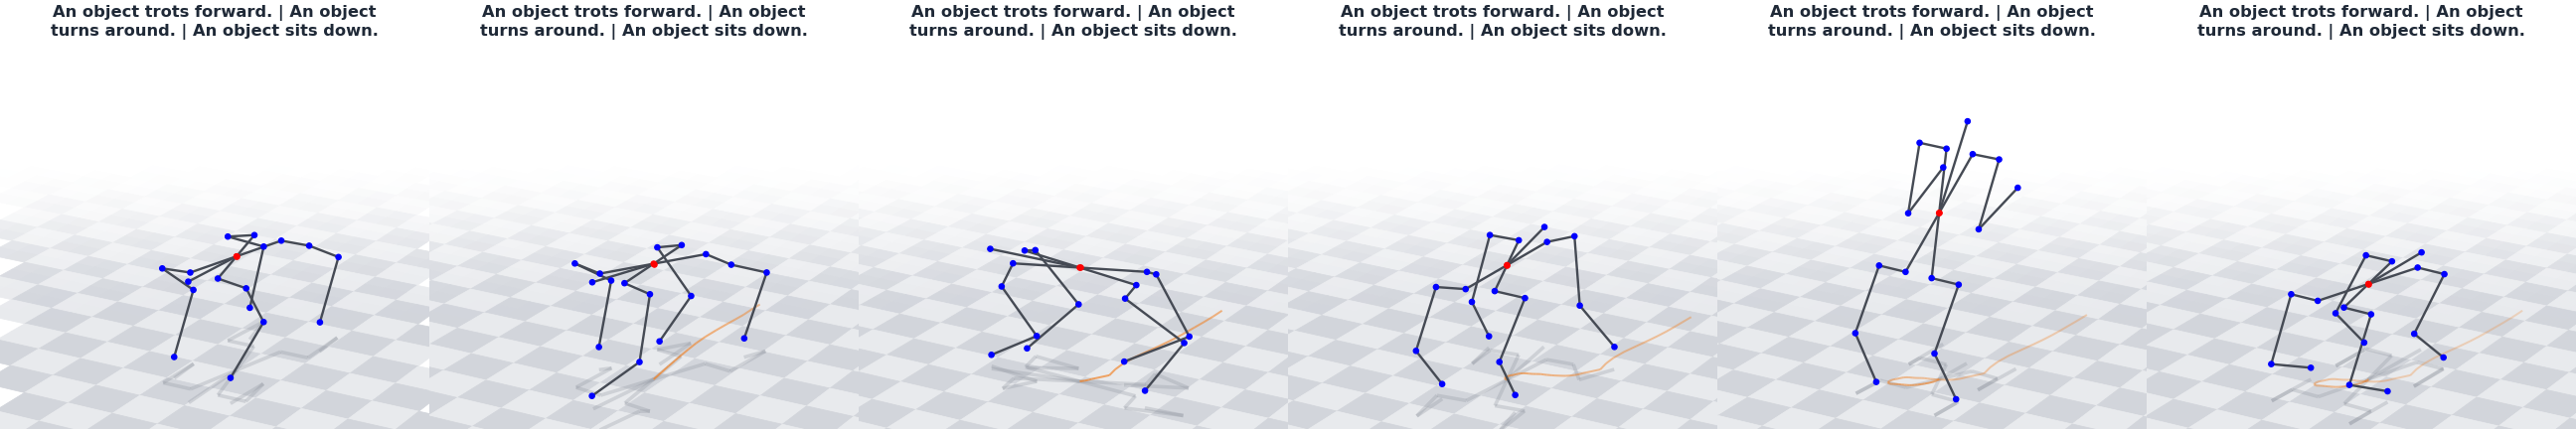
Quick start
BASE=https://townbox-unimate-for-agents.hf.space
# 1. the skeletons (unitree_go2, eagle, shark, or upload your own)
curl -s -H "Authorization: Bearer $HF_TOKEN" $BASE/api/assets

# 2. generate (about 10 s; GPU time goes to your ZeroGPU quota)
curl -s -X POST $BASE/api/animate -H "Authorization: Bearer $HF_TOKEN" -H 'content-type: application/json' \
  -d '{"asset": "unitree_go2", "prompt": "An object trots forward.", "num_samples": 2, "seed": 7}'

# 3. download the animated mesh, the joint positions, the raw features
curl -s -H "Authorization: Bearer $HF_TOKEN" -o trot.glb "$BASE/api/jobs/<job_id>/files/sample0_animation.glb"

# 4. keep what you like, regenerate the rest (reference = that job_id), or chain prompts
curl -s -X POST $BASE/api/inbetween -H "Authorization: Bearer $HF_TOKEN" -H 'content-type: application/json' \
  -d '{"reference_job_id": "<job_id>", "keep_frames": "0,-1", "prompt": "An object jumps in place."}'
curl -s -X POST $BASE/api/edit -H "Authorization: Bearer $HF_TOKEN" -H 'content-type: application/json' \
  -d '{"reference_job_id": "<job_id>", "keep_joints": "Left Back Thigh, Right Back Thigh, Left Back Shin, Right Back Shin", "prompt": "An object rears up on its hind legs."}'
curl -s -X POST $BASE/api/expand -H "Authorization: Bearer $HF_TOKEN" -H 'content-type: application/json' \
  -d '{"asset": "unitree_go2", "prompts": ["An object trots forward.", "An object turns around.", "An object sits down."], "overlap": 10}'
Beyond one prompt
The three editing modes of the upstream inference code, exposed as they are implemented there: the kept part of a reference motion is pinned at every step of the flow ODE and the rest is denoised under the prompt (fixed-step Euler, 50 steps). Same parameters and result shape as /api/animate; cfg_scale must be above 1.0. Each was verified on this Space: the kept frames or joints come back identical to the reference, the expansion is continuous over its pinned overlaps and its 160-frame GLB matches Blender's importer.
POST /api/inbetweenMCP
inbetweenkeep_frames of an earlier result (indices into its 60-frame window, negatives from the end; default "0,-1", first and last frame) and regenerate every other frame under prompt. Reference: reference_job_id, reference_sample, reference_start (window start, for the longer expansion results). Returns the resolved keep_frames and generated_frames. Upstream --inbetween --keep_frames.POST /api/editMCP
edit_jointskeep_joints of an earlier result over the whole clip (joint names or anatomical labels from /api/assets, case-insensitive; a label such as “Left Wing” selects every joint carrying it) and regenerate the other joints under a new prompt: keep the legs of a walk, ask for flapping wings. Returns keep_joints and edited_joints. Upstream --motion_edit --keep_joints.POST /api/expandMCP
expandprompts into one motion: one 60-frame segment each, every further segment generated with its first overlap frames (default 10) pinned to the previous segment's last frames, in its own forward-facing frame and rotated back, so turns carry over. 60 + 50 frames per extra prompt in one GLB, .npy and JSON; returns segments with each prompt's frame range. Measured on the trot → turn → sit chain: the first regenerated frame after a seam can pop (a 33° facing change at the trot-to-turn seam with overlap 10; larger overlaps made it worse), so keep the default overlap and re-run with another seed when a seam shows. Upstream --motion_expand --expand_overlap.Endpoints
GET /api/assetsPOST /api/assetsrig_preprocess output (cond.npy + canonical GLB) of your own rig; returns a u_… id.POST /api/animate{asset, prompt, num_samples?, cfg_scale?, seed?, preview?}. Returns the result with a URL per output file and ready-made next bodies for the modes below.POST /api/inbetween{reference_job_id, reference_sample?, reference_start?, keep_frames?, prompt, …}. Kept frames stay, the others are regenerated.POST /api/edit{reference_job_id, reference_sample?, reference_start?, keep_joints, prompt, …}. Kept joints stay, the others are regenerated.POST /api/expand{asset, prompts[], overlap?, …}. One long motion from several prompts; num_samples × prompts ≤ 8 per call.GET /api/jobs/{job_id}/api/jobs/{job_id}/files/{name}.GET /api/examplesGET /api/identityGET /api, /api/healthMCP tools: animate, inbetween, edit_joints, expand, list_assets, get_result, view_animation (returns the contact-sheet PNG), service_info, guide.
Parameters
asset/api/assets.promptnum_samplescfg_scaleseedpreviewreference_job_id, reference_sample, reference_startkeep_frames"0,-1").keep_jointspromptsoverlapOutputs per sample
unimate.inference.sample writes.Model and provenance
UniMate: One Unified Model to Animate Diverse Skeletons. Linzhan Mou, Jiahui Lei, Zhiyang Dou, Chenyue Cai, Chaoyue Song, Adam Finkelstein, Szymon Rusinkiewicz. SIGGRAPH Asia 2026. arXiv 2609.05415 · project page · code (MIT) · checkpoints (CC BY-NC 4.0)
This service runs the released checkpoint unimate_uniml3d_f60_v3/checkpoints/checkpoint_step_150000.pt (EMA weights, 74M-parameter topology-aware flow-matching transformer, 50 ODE steps with classifier-free guidance) with the frozen google/flan-t5-base text encoder, through the repository's own inference code at commit b78c7807: unimate.inference.generate for text-to-motion and its motion_inbetweening, motion_editing and motion_expansion modules for the three editing modes. The animated GLB comes from a Blender-free glTF baker that applies the generated joint transforms to the asset's canonical rest-pose GLB; it was checked against Blender's glTF importer (joint positions agree to 1e-5 over every frame).
Weights are for non-commercial research use (CC BY-NC 4.0); the training data (Truebones ZOO, Mixamo, Objaverse-XL) keep their own terms, see the model card. The project page's 3D showcase is access-controlled and is not used by this service; every output is generated live.